 By
For more than half a century, the humanoid robot was a staple of science fiction and choreographed laboratory demos. Early walking platforms exhibited rigid, pre-programmed gaits, stumbled over minor floor variations, and required tethered power cords and external server racks. A change in object position or a sudden nudge meant an inevitable system freeze or a catastrophic fall.
That era of brittle mechanical theater has ended.
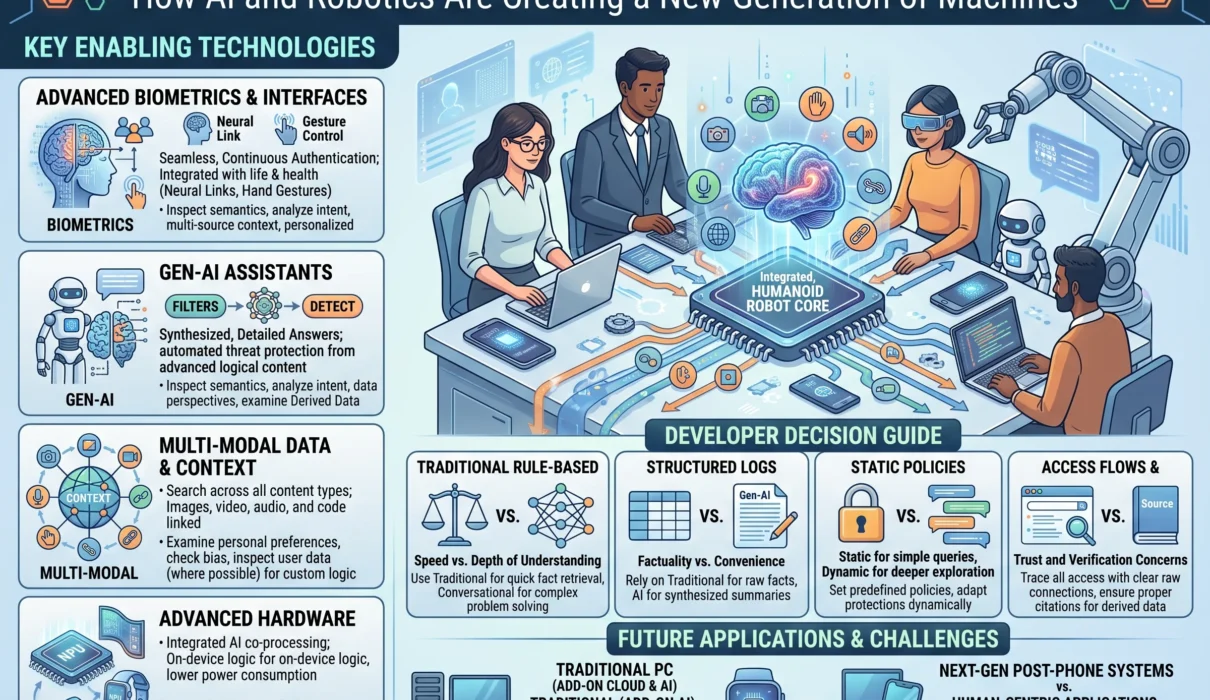
We are witnessing a transformative convergence: modern deep learning architectures have met advanced electromechanics, creating true humanoid robots. Driven by multimodal Vision-Language-Action (VLA) foundation models, high-torque quasi-direct drive actuators, tactile electronic skin, and real-time spatial navigation, AI robots are stepping out of research institutions and onto active commercial factory floors.
The commercialization of robotics technology is no longer restricted to bolted-down robotic arms in fenced safety cages. The world is built for humans: our doorways, stairwells, industrial shelving, vehicle cabins, and hand tools are engineered for a bipedal form factor with two arms and dexterous hands. Deploying a general-purpose bipedal machine bypasses the multi-million-dollar structural retrofits required for traditional automation.
Understanding how future robots perceive dynamic environments, balance across uneven terrain, manipulate fragile objects, and integrate into enterprise supply chains requires analyzing the entire hardware and software stack powering the modern humanoid revolution.
THE EVOLUTION OF INDUSTRIAL ROBOTIC SYSTEMS

Phase 1: Deterministic Automation (1970s–2010s)
┌─────────────────────────────────┐
│ Caged Robotic Arms / Fixed AGVs │  • Blind execution of static trajectory code
│ Bolted to factory floor         │  • Zero spatial perception; hard stops on errors
└─────────────────────────────────┘
                │
                ▼
Phase 2: Collaborative Robotics / Cobots (2015–2023)
┌─────────────────────────────────┐
│ Power-Limited Robotic Arms      │  • Force-torque sensing allows human co-working
│ Fixed pedestals / wheeled bases │  • Task-specific programming; limited locomotion
└─────────────────────────────────┘
                │
                ▼
Phase 3: Embodied General-Purpose Humanoids (Present & Beyond)
┌────────────────────────────────────────────────────────────────────────┐
│ BIPEDAL EMBODIED AI WORKER (Figure, Tesla Optimus, Boston Dynamics)    │
│ • End-to-end Vision-Language-Action (VLA) neural control               │
│ • Unstructured 3D navigation across stairs, ramps, and narrow aisles   │
│ • High-dexterity tactile hands operating standard human hand tools     │
└────────────────────────────────────────────────────────────────────────┘
1. Why the Humanoid Form Factor? The Architectural Logic
The question robotics engineers face most often is straightforward: Why build a complex bipedal robot when wheeled carts and fixed arms are mechanically simpler?
The answer lies in the concept of brownfield infrastructure.
Human civilization has spent centuries designing physical environments around human ergonomics:
- Factory lines feature stairs, mezzanines, and catwalks that wheeled Automated Guided Vehicles (AGVs) cannot climb.
- Industrial shelves are stacked vertically, requiring an entity capable of crouching down to floor-level pallets and reaching overhead bins.
- Hand tools—wrenches, adhesive spray guns, calipers, and power drills—are engineered for human palms and fingers.
┌────────────────────────────────────────────────────────────────────────┐
│                   WHEELED AGVs vs. BIPEDAL HUMANOIDS                   │
├─────────────────────┬────────────────────┬─────────────────────────────┤
│ Operational Feature │ Wheeled Mobile AGV │ Bipedal Humanoid Robot      │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Architectural Fit   │ Requires greenfield│ Deploys directly into       │
│                     │ ramps, flat floors,│ legacy brownfield plants,   │
│                     │ and wide hallways  │ stairs, and narrow aisles   │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Vertical Reach      │ Fixed vertical mast│ Dynamic squatting, bending, │
│                     │ with limited range │ reaching, and torso twisting│
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Task Scope          │ Dedicated single-  │ Universal: moves totes,     │
│                     │ task (tote hauling)│ seats wire harnesses, bolts │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Tool Adaptability   │ Specialized custom │ Directly utilizes standard  │
│                     │ mechanical fixtures│ off-the-shelf human tools   │
└─────────────────────┴────────────────────┴─────────────────────────────┘
Transforming an existing automotive assembly plant into a fully automated “lights-out” facility using specialized machinery often costs hundreds of millions of dollars in capital expenditure (CapEx) and requires months of halted production.
A general-purpose humanoid robot is an architectural drop-in replacement. It walks through the same security turnstiles, navigates the same cluttered assembly corridors, manipulates parts using the same fixtures, and hands components directly to human coworkers without requiring factory rebuilds.
2. Sensory Perception: How Modern Humanoids See and Feel
A humanoid robot cannot calculate stable footsteps or pick up a component if its perception of reality is noisy, slow, or distorted. In modern robotics technology, sensor stacks must construct an accurate, latency-free 3D representation of the physical world while maintaining high frame rates under varying lighting conditions.
                     THE MULTIMODAL PERCEPTION PIPELINE

  [High-Resolution Stereo RGB Cameras] ──┐
  [Solid-State Micro-LiDAR Arrays]     ──┼─► [Sensor Fusion & Temporal Filter]
  [Capacitive Tactile Finger Arrays]   ──┤                 │
  [High-Frequency 6-Axis IMUs]         ──┘                 ▼
                                             [Real-Time 3D Volumetric Mesh]
                                             • Semantic entity classification
                                             • Sub-millimeter depth mapping
                                             • Shear force & slip vectors
1. Vision: Stereoscopic RGB and Solid-State LiDAR
Modern humanoids discard bulky spinning mechanical LiDAR domes on their heads in favor of flush, integrated sensor suites:
- Stereoscopic RGB Cameras: Mounted in the robot’s head, stereo cameras utilize parallax disparity to estimate geometric depth, providing high-resolution color information that allows vision models to read labels, inspect surface finishes, and identify component boundaries.
- Wide-Angle Fisheye Peripheral Sensors: Embedded along the torso and hips to provide 360-degree situational awareness, ensuring the robot does not swing its elbows or step backward into human coworkers or moving forklifts.
- Solid-State Time-of-Flight (ToF) and Flash LiDAR: Emits instantaneous laser pulses to return millimeter-accurate spatial point clouds. Unlike optical cameras that can struggle in dim shadows, high glare, or direct sunlight, LiDAR provides consistent distance measurements regardless of ambient lighting conditions.
2. Tactile Perception: Electronic Skin and Force Sensing
Vision tells a robot where an object is; tactile sensing tells the robot how to hold it without dropping or crushing it.
Earlier iterations of robotic hands utilized binary touch switches or relied entirely on motor current draw to guess grip force. Modern dexterous humanoid end-effectors incorporate electronic tactile skin:
- Capacitive & Piezoresistive Micro-Arrays: Embedded into the silicone pads of each fingertip and palm, thousands of microscopic sensor cells measure normal pressure and shear stress distributions.
- Micro-Slip Detection: When a heavy metal bracket or smooth glass beaker begins to slip from the robot’s grasp, tactile sensors detect micro-vibrations across the skin surface in fractions of a millisecond. The onboard motor control loop instantly tightens grip torque before the object falls.
- 6-Axis Force-Torque Sensors in Wrists and Ankles: Measure rotational and translational stress vectors. In the ankles, these sensors feed continuous ground-reaction force data into the bipedal locomotion controller to adjust foot strike angles on uneven terrain.
3. Inertial Measurement Units (IMUs)
Equipped with high-frequency MEMS gyroscopes and accelerometers positioned within the pelvis and head, IMUs operate at frequencies exceeding 1,000 Hz. They provide real-time gravitational orientation, rotational acceleration, and velocity tracking, serving as the biological equivalent of the human inner ear’s vestibular system to preserve dynamic equilibrium.
3. The AI Brain: Vision-Language-Action (VLA) Foundation Models
The fundamental breakthrough turning mechanical skeletons into autonomous AI robots is the evolution of artificial intelligence from static text generators into Vision-Language-Action (VLA) models.
Historically, robotic intelligence was fractured into disconnected software silos: one computer vision pipeline identified bounding boxes, a rule-based logic engine decided what to do, an inverse-kinematics solver calculated trajectory paths, and a low-level PID controller moved the joints. This pipeline was brittle: if the vision system misclassified a shadowed object, downstream motion planners failed immediately.
THE ARCHITECTURAL SHIFT IN ROBOTIC CONTROL

Legacy Pipeline Control (Brittle, Disconnected):
[Camera Feed] ──► [Object Detector] ──► [Motion Planner] ──► [IK Solver] ──► [Joint Move]
(A failure in any isolated software module crashes the entire task execution chain)

Modern Vision-Language-Action (VLA) End-to-End Control:
┌────────────────────────────────────────────────────────────────────────┐
│ UNIFIED MULTIMODAL EMBODIED TRANSFORMER (e.g., RT-2, OpenVLA, Helix)   │
├────────────────────────────────────────────────────────────────────────┤
│ Visual Tokens (Camera Patches) + Language Tokens ("Pick up the drill") │
├────────────────────────────────────────────────────────────────────────┤
│ Deep Cross-Attention Reasoning Layers (Web-Scale Common Sense)         │
├────────────────────────────────────────────────────────────────────────┤
│ Direct Action Token Emission: 6-DoF End-Effector Poses & Joint Deltas  │
└──────────────────────────────────┬─────────────────────────────────────┘
                                   │
                                   ▼
             [High-Frequency Visuomotor Control Loop (100–200 Hz)]
From Next-Word Prediction to Next-Action Prediction
Modern language models process text by predicting the next logical token in a sequence. VLA models expand this concept by treating physical robotic actions as tokens:
- Multimodal Ingestion: The network ingests visual camera frames (encoded as visual patch tokens via a Vision Transformer) alongside natural language instructions.
- Embodied Semantic Reasoning: Because the model’s core transformer was pre-trained on internet-scale multimodal datasets, it possesses generalized physical common sense. If you command: “Clean up the spill,” it recognizes that a rock is solid, an empty mug will not absorb liquid, and a fibrous sponge is the correct physical tool to grab.
- Action Chunking and Tokenization: Instead of outputting text, the model’s action head predicts continuous trajectory tokens—spatial end-effector offsets, wrist orientations, and finger closures. Through action chunking, the model emits sequences of future physical steps in a single decoding pass, amortizing computational overhead while maintaining high execution smoothness.
Dual-System Cognitive Architectures (System 1 vs. System 2)
A major engineering challenge with foundation models is latency. A 7-billion parameter VLA model might take 100 to 200 milliseconds to process a forward pass. While acceptable for strategic planning, waiting 200 milliseconds to adjust motor torque while balancing on one foot will cause a 150-pound bipedal robot to collapse.
Leading commercial humanoid architectures resolve this through hierarchical dual-system orchestration:
                     HIERARCHICAL COGNITIVE ORCHESTRATION

  SYSTEM 2: High-Level Semantic Reasoning (~2 Hz to 10 Hz)
  • Large multimodal VLA model running on edge GPUs
  • Parses environment, identifies tasks, and decomposes complex goals
  • Emits high-level Cartesian trajectory waypoints and object approach vectors
                             │
                             ▼
  SYSTEM 1: Low-Level Visuomotor Control (~100 Hz to 1,000 Hz)
  • Compact, distilled neural policies & Model Predictive Control (MPC)
  • Runs deterministically on dedicated microcontrollers & RTOS
  • Compensates for micro-stumbles, slip dynamics, joint torque balancing
- System 2 (Slow, Semantic Deliberation): A large VLA model operates at 2 to 10 Hz. It surveys the scene, tracks high-level operational goals, navigates around obstacles, and calculates target trajectory waypoints for picking up a designated tool.
- System 1 (Fast, Reflexive Execution): A compact, distilled policy network operating alongside Model Predictive Control (MPC) algorithms executes at 200 to 1,000 Hz. It manages the physics of balance, regulates motor currents, and maintains grip stability. If a box unexpectedly shifts weight in the robot’s hands, System 1 adjusts arm tension in milliseconds without waiting for System 2 to complete another full visual reasoning cycle.
4. Actuators and Mechatronics: The Muscle Powering the Machine
An artificial intelligence model can calculate ideal movements, but physical execution is constrained by mechatronics. The physical capabilities of a humanoid robot—its speed, payload capacity, energy efficiency, and safety around humans—are governed by its actuators.
For decades, robotics relied on either noisy, high-pressure hydraulic cylinders or stiff, high-ratio geared motors. Modern humanoid platforms have standardized on advanced electromechanical actuation systems.
┌────────────────────────────────────────────────────────────────────────┐
│                   ACTUATOR ARCHITECTURES COMPARED                      │
├─────────────────────┬────────────────────┬─────────────────────────────┤
│ Actuator Technology │ Mechanical Profile │ Key Trade-offs in Humanoids │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Hydraulic Actuators │ High power density;│ Leaks fluid, noisy, high    │
│ (Legacy Atlas v1)   │ extreme dynamic    │ idle power draw; largely    │
│                     │ burst forces       │ abandoned in commercial units│
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ High-Ratio Geared   │ High holding torque│ Zero back-drivability; rigid│
│ Electric Motors     │ using planetary or │ impacts damage gear teeth;  │
│                     │ strain-wave drives │ hazardous around humans   │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Quasi-Direct Drive  │ High-torque BLDC   │ Highly back-drivable; safe, │
│ (QDD) Electric      │ with low-ratio     │ energy-efficient; larger,   │
│ Actuators           │ gear reduction     │ heavier motor diameters    │
├─────────────────────┼────────────────────┼─────────────────────────────┤
│ Linear Roller-Screw │ Converts rotation  │ Extremely high linear force │
│ Actuators           │ to linear thrust   │ for knees, hips, and dynamic│
│                     │ with high rigidity │ lift joints                 │
└─────────────────────┴────────────────────┴─────────────────────────────┘
The Transition to All-Electric Systems
Early dynamic humanoids relied on hydraulic actuators because fluid power delivered the power-to-weight ratios required for acrobatic jumps and backflips.
However, hydraulics are ill-suited for commercial factory deployment: they require pressurized fluid pumps that consume significant power at idle, generate noise, require frequent hose maintenance, and risk leaking toxic hydraulic oil onto clean factory floors.
The industry has converged on all-electric architectures. Advances in high-energy-density Neodymium magnets, specialized field-oriented motor control (FOC) algorithms, and custom planar coil windings allow electric motors to match the burst forces of legacy hydraulics while operating quietly and cleanly.
ANATOMY OF A QUASI-DIRECT DRIVE (QDD) ROBOTIC JOINT

[High-Torque Brushless DC (BLDC) Motor]
                 │
                 ▼
[Low-Ratio Planetary Gearbox (typically 6:1 to 10:1)]
                 │
                 ▼
[Dual High-Resolution Optical/Magnetic Encoders]
                 │
                 ▼
[Mechanical Output Linkage]
  • Low rotational inertia allows instantaneous joint acceleration
  • Impact forces push backwards through the gear teeth (Back-drivable)
  • Eliminates brittle gear shear during external collisions
Quasi-Direct Drive (QDD) and Physical Compliance
When a human walks down a flight of stairs or catches a heavy falling object, our muscles and tendons act as biological shock absorbers. Traditional industrial robots were built with high gear ratios (100:1 or 200:1), creating stiff, unyielding joints: if the robot arm bumped into a concrete wall or a human shoulder, the shock force transferred directly into the gear teeth, shearing the steel components or causing severe injury.
Modern humanoids utilize Quasi-Direct Drive (QDD) actuators:
- By pairing oversized, high-torque brushless DC motors with low-ratio gearsets (typically under 10:1), the joint remains mechanically back-drivable.
- If an external force strikes the arm, the joint physically gives way and moves backward.
- The motor controller reads the electromagnetic back-EMF and current deflection, allowing the system to measure and respond to external contact forces in milliseconds without requiring fragile external load cells. This mechanical compliance is the foundation of physical workplace safety.
Degrees of Freedom (DoF) Distribution
A modern commercial humanoid robot typically incorporates between 28 and 56 active Degrees of Freedom (DoF) across its skeleton:
- Legs & Pelvis (12–14 DoF): Hip pitch/roll/yaw, knee flexion, ankle pitch/roll, allowing dynamic bipedal balancing, squatting, and omnidirectional turning.
- Torso & Neck (3–5 DoF): Torso yaw and tilt to extend manipulation reach and shift center-of-mass balance; neck pan/tilt to direct sensory focal points.
- Arms & Shoulders (14–16 DoF): Shoulder pitch/roll/yaw, elbow flexion, forearm rotation, and multi-axis wrist articulation designed to match human ranges of motion.
- Dexterous Hands (12–24 DoF): Actuated fingers utilizing miniature tendon-driven linkages or embedded palm motors, enabling individual finger articulation, adaptive grasping, and fine tool manipulation.
5. Locomotion and Navigation: The Physics of Balance
Bipedal walking is one of the most complex mechanical challenges in robotics.
Human locomotion is not a stable static posture; it is a continuous, controlled forward fall. During roughly 60% of every walking stride cycle, a biped is supported by a single foot, meaning the system’s center of pressure must be actively balanced over a narrow base of support.
                     THE BIPEDAL BALANCE FEEDBACK LOOP

  [Zero-Moment Point (ZMP) & Center of Mass Calculation]
                           │
                           ▼
  [Model Predictive Control (MPC) Horizon Solver (~500 Hz)]
  • Simulates next 1.5 seconds of physical movement steps
  • Solves quadratic optimization for ground reaction forces
                           │
                           ▼
  [Deep Reinforcement Learning (RL) Whole-Body Controller]
  • Dynamically absorbs ground variations and surface slips
  • Distributes torque across hip, knee, and ankle actuators
                           │
                           ▼
  [Physical Foot Strike & Ground Contact Reaction]
1. From ZMP to Deep Reinforcement Learning
Historically, bipedal locomotion relied strictly on the Zero-Moment Point (ZMP) criterion—an analytical approach where the robot placed its feet flatly, slowly, and cautiously to ensure that all inertial and gravitational forces pointed directly into the footprint boundary. This produced the slow, bent-knee, shuffling walk seen in early experimental platforms.
Modern humanoids utilize a combination of Model Predictive Control (MPC) and Deep Reinforcement Learning (RL) trained inside physics engines:
- The neural network is subjected to simulated physical disruptions: shove impulses, slippery surfaces, uneven obstacles, and tripping hazards across billions of training iterations.
- The system learns emergent biological locomotion: striking with the heel, rolling across the foot, pushing off with the toe, dynamically swinging arms for angular momentum cancellation, and crossing legs to catch balance during unexpected shoves.
2. Spatial Navigation: SLAM and Real-Time Pathfinding
To move through an expansive manufacturing plant or warehouse, humanoids combine local locomotion with global spatial navigation:
- Visual-Inertial Odometry (VIO) & SLAM: Simultaneous Localization and Mapping algorithms combine high-rate IMU telemetry with optical point clouds, building a continuous millimeter-scale 3D mesh of the environment while tracking the robot’s coordinate location within that space.
- Dynamic Cost-Map Pathfinding: If a forklift parks in a primary hallway, the pathfinding engine updates the local 3D cost-map, dynamically routing the robot around the blockage while verifying that floor clearance, overhead pipe heights, and footing stability satisfy safety constraints.
6. Industrial Deployments: Where Humanoids Work Today
The transition of humanoid robots from viral laboratory video demonstrations to paid production deployment has accelerated significantly.
Industrial enterprises have moved past non-committal pilot tests into structured, multi-shift production roles.
┌────────────────────────────────────────────────────────────────────────┐
│                   COMMERCIAL HUMANOID PRODUCTION ROLES                 │
├─────────────────────┬──────────────────────────────────────────────────┤
│ Operational Domain  │ Specific Industrial Workflow Tasks                │
├─────────────────────┼──────────────────────────────────────────────────┤
│ Automotive Assembly │ Kitting parts, seating delicate wire connectors, │
│ Plants (BMW, Tesla) │ sheet metal transfer, high-voltage battery packs│
├─────────────────────┼──────────────────────────────────────────────────┤
│ Logistics Hubs      │ Tote unstacking, parcel induction, palletizing,  │
│ (Amazon, GXO)       │ mixed-sku sortation to autonomous carts         │
├─────────────────────┼──────────────────────────────────────────────────┤
│ Heavy Manufacturing │ Moving parts between isolated CNC machining cells│
│ & Foundries         │ where fixed conveyor belts are impractical       │
├─────────────────────┼──────────────────────────────────────────────────┤
│ Electronics & Clean │ Transporting delicate silicon wafer carriers and │
│ Sub-Assembly        │ circuit boards between cleanroom processing bays │
└─────────────────────┴──────────────────────────────────────────────────┘
Automotive Manufacturing Deployments
Automakers have become the primary proving ground for humanoid robotics:
- BMW Spartanburg Facility: Commercial deployments of Figure’s bipedal humanoids (Figure 02 and Figure 03) run structured ten-hour material handling shifts, transferring stamped sheet metal chassis parts with over 99% placement accuracy directly into assembly fixtures—operating at documented commercial costs near $25 per operating hour.
- Tesla Gigafactories: Deploying fleets of Optimus Gen 3 humanoids across internal battery assembly cells, carrying component containers, seating electrical wire connectors, and loading EV battery packs onto automated automated logistics tracks.
Logistics and Supply Chain Fulfillment
In distribution facilities (such as Amazon logistics hubs deploying Agility Robotics’ Digit), humanoids bridge the gap between static storage racks and sorting conveyors:
- Moving plastic totes weighing up to 35 pounds from high-density autonomous storage racks and transferring them directly onto conveyor belts.
- Operating in facilities built for human workers without requiring multi-million-dollar retrofits or fixed automated sorting structures.
7. Critical Challenges: The Engineering and Economic Hurdles
Despite technical momentum, humanoid robotics operates at the absolute frontier of mechanical engineering, energy storage, and computational efficiency. Widespread adoption faces four critical constraints:
                      THE HUMANOID ENGINEERING BOTTLENECK

        Energy Density & Runtime               Hardware Durability & MTBF
       ┌────────────────────────┐             ┌────────────────────────┐
       │ 2–4 kWh batteries yield│             │ 40+ dynamic joints     │
       │ only 2–4 hours of heavy│ ──────────► │ mean high wear rates;  │
       │ walking and lifting.   │             │ MTBF must reach 10,000+│
       └────────────────────────┘             │ operating hours.       │
                                 │            └────────────────────────┘
                                 ▼
                     Manufacturing Unit Economics
                    ┌────────────────────────────┐
                    │ Current builds: $80K–$150K;│
                    │ must decline to $20K–$30K  │
                    │ to achieve broad payback. │
                    └────────────────────────────┘
1. Energy Density and Battery Runtime
A human being walking and carrying boxes consumes roughly 100 to 200 watts of metabolic energy. A 150-pound metal and carbon-fiber humanoid robot performing identical physical tasks consumes between 800 and 1,500 watts of continuous electrical power to run high-torque motors, cooling fans, camera pipelines, and onboard tensor processors.
- Current humanoid battery packs typically hold 2 to 4 kWh of energy using lithium-ion chemistry.
- This provides an operational runtime of roughly 2 to 4 hours under heavy industrial duty cycles before requiring a recharge.
- To maintain continuous three-shift factory operations, manufacturers must design automated battery hot-swapping stations or autonomous self-docking high-amperage rapid-charging systems that top up batteries during scheduled worker breaks.
2. Hardware Durability and Mean Time Between Failures (MTBF)
Industrial automation equipment is expected to run 24 hours a day, 365 days a year, with a Mean Time Between Failures (MTBF) exceeding 20,000 to 50,000 hours.
A humanoid robot contains over 30 to 40 individual electric motors, harmonic reduction gearboxes, bearing races, planetary rollers, and internal wire harnesses. If an actuator experiences mechanical gear fatigue or a high-flex wrist cable snaps after 1,000 operating hours, factory maintenance downtime rapidly destroys the business case for deployment. Improving cycloidal gear durability, bearing seals, and heat dissipation is an essential prerequisite for scale.
3. The Unit Economics Curve
For humanoids to replace or augment human labor at scale, the total cost of ownership (TCO) must make economic sense:
- Early commercial prototypes cost between $150,000 and $250,000 per unit. At that price point, positive return on investment (ROI) was achievable only in high-risk ergonomic stations characterized by worker injuries and high turnover.
- As volume manufacturing scales, the industry is targeting commercial hardware costs of $20,000 to $30,000 per unit.
- Reaching this cost curve collapses the payback timeline to under 6 to 12 months, shifting humanoid adoption from an experimental R&D initiative into a standard corporate procurement decision.
8. Safety, Standards, and Workplace Integration
Deploying a mobile, 150-pound autonomous machine capable of exerting heavy forces alongside human factory workers introduces real safety considerations.
                     THE LAYERED ROBOTIC SAFETY MODEL

  [LAYER 1: DETERMINISTIC MECHANICAL COMPLIANCE]
  Quasi-Direct Drive (QDD) actuators yield mechanically upon physical contact.

  [LAYER 2: LOW-LATENCY SENSORY ZONATION]
  Visual, LiDAR, and capacitive proximity monitoring creates dynamic safety halos.
  Speed scales down proportionally as human workers step closer.

  [LAYER 3: HARDWARE SAFETY CIRCUIT INTERLOCKS]
  Dedicated, SIL-rated safety controllers override AI models; physical E-stops.
Safety Certifications: ISO 10218 and ISO/TS 15066
Humanoid robots operating in commercial environments must comply with international industrial safety mandates:
- ISO 10218: Establishes safety requirements for industrial robots, defining parameters for protective stops, path validation, and system fault containment.
- ISO/TS 15066: Specifies collaborative robot (cobot) guidelines, setting mathematical thresholds for transient and quasi-static contact forces. If a humanoid’s arm inadvertently makes physical contact with a human worker’s chest or hand, the peak kinetic energy and pressure must remain below legally mandated thresholds to prevent bruising or crushing injuries.
Deterministic Safety Envelopes Over AI Models
Modern deep learning foundation models operate probabilistically. Because an AI model cannot be guaranteed to never hallucinate an invalid motor command, the AI is never given unmonitored control over safety-critical actuator power lines.
Industrial humanoids implement deterministic supervisory monitoring:
- A certified safety controller continuously evaluates the trajectory, joint velocities, and balance vectors emitted by the AI neural network.
- If the neural network recommends a motion that violates geometric safety zones, approaches a human coworker too quickly, or exceeds joint velocity limits, the safety architecture intervenes in hardware—overriding the AI model and safely slowing or braking the joints without dropping the robot to the floor.
9. Strategic Enterprise Implementation Blueprint
Deploying humanoid robots into an existing enterprise manufacturing plant or distribution facility requires a disciplined integration plan. Rushing unverified machines into unstructured environments leads directly to operational frustration.
┌────────────────────────────────────────────────────────────────────────┐
│               HUMANOID ROBOT DEPLOYMENT ROADMAP                        │
├─────────────────────┬──────────────────────────────────────────────────┤
│ Implementation Gate │ Core Engineering & Operational Mandate           │
├─────────────────────┼──────────────────────────────────────────────────┤
│ Gate 1: Workflow    │ Identify structured, repetitive material flows   │
│ Scoping             │ (tote transfers, kitting, sub-assembly logistics)│
├─────────────────────┼──────────────────────────────────────────────────┤
│ Gate 2: Digital     │ Construct a physically accurate OpenUSD digital  │
│ Simulation (Twin)   │ twin of the cell; train VLA policies in sim    │
├─────────────────────┼──────────────────────────────────────────────────┤
│ Gate 3: Controlled  │ Deploy 1–3 units alongside specialized vendor    │
│ Pilot Validation    │ support; benchmark MTBF, cycle times, and uptime│
├─────────────────────┼──────────────────────────────────────────────────┤
│ Gate 4: Fleet Scale │ Expand to full-shift production runs; integrate  │
│ & Systems Handshake │ Fleet Management APIs into existing MES and WMS  │
└─────────────────────┴──────────────────────────────────────────────────┘
- Target the Automation “Sweet Spot”: Do not attempt to automate high-speed, high-precision tasks like arc welding or stamping—fixed industrial robot arms handle those operations with far higher speed and precision. Deploy humanoids where tasks change station-to-station, parts arrive in mixed batches, and fixed automation would require continuous, expensive reprogramming: kitting, bin picking, parts transfer, and machine tending.
- Standardize Fleet Management Software: A factory will rarely deploy humanoids from only a single vendor. Ensure your robotics architecture interfaces via open APIs (such as ROS 2, VDA 5050, or centralized Warehouse Execution Systems), allowing your dispatch software to assign tasks across heterogeneous robot fleets uniformly.
- Reskill Floor Labor into Fleet Supervisors: The deployment of intelligent robots does not eliminate human factory teams; it shifts their operational role. Train existing floor technicians to become robotic fleet handlers—technicians who monitor robot health, handle non-standard material exceptions, swap modular end-effectors, and supervise autonomous workflows across the line.
The Physical Embodiment of Intelligence
For decades, the fields of artificial intelligence and robotics developed on parallel, separated paths. Computer scientists built advanced algorithms that processed information within data centers, while mechanical engineers built rigid steel machines that followed hardcoded coordinates inside safety cages.
Humanoid robots represent the fusion of those two disciplines.
By pairing multimodal AI models with advanced actuators, spatial navigation, and human-grade sensors, the technology sector is producing a new generation of machines capable of understanding and interacting with physical reality.
The transition from lab demonstrations to full-scale commercialization will not happen in a single, overnight flash. It is unfolding through structured industrial validation: hauling totes, kitting automotive parts, and assisting manufacturing assembly lines with measurable repeatability.
The humanoid robot is not a novelty or an automated gimmick. It is the natural mechanical form for embodied artificial intelligence in a human-built world—a general-purpose tool that will augment human labor, expand industrial productivity, and help construct the physical future.